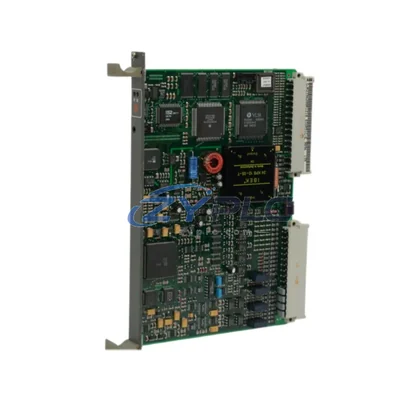
ABB 3HAC024775-001 Serial Measurement Board IRC5: Precision Motor Control for Optimized Automation
The ABB 3HAC024775-001 Serial Measurement Board (SMB) is a critical feedback and measurement module engineered for ABB IRC5 robot controllers. Designed to deliver accurate encoder signal processing and axis position data, this board plays a foundational role in reducing unnecessary motor corrections, minimizing reactive energy consumption, and maintaining tight synchronization across all robot axes. In high-throughput manufacturing environments where every millisecond and every watt counts, the 3HAC024775-001 SMB ensures that the IRC5 drive system operates at peak efficiency — eliminating unplanned downtime caused by positional drift, erratic axis feedback, or degraded signal integrity.
For factories running continuous production cycles, the SMB directly influences the energy profile of the entire robot cell. When encoder feedback is clean and latency-free, the IRC5 controller can issue precise torque commands to each servo drive, preventing the overcorrection cycles that silently inflate energy bills. Replacing a worn or failing 3HAC024775-001 with a tested, verified unit is one of the most cost-effective interventions available to maintenance engineers seeking to restore optimal drive efficiency without capital investment in new equipment.
Product Specification Table
| Parameter |
Specification / Value |
| Part Number |
3HAC024775-001 (Alt: 3HAC044168-001) |
| Compatible Controller |
ABB IRC5 (Single Cabinet, Dual Cabinet, Panel Mounted) |
| Function |
Serial Measurement Board — Axis Encoder Feedback & Position Data |
| Drive Efficiency Impact |
Reduces unnecessary servo corrections, lowers reactive torque demand |
| Compatible Robot Series |
IRB 1600, IRB 2400, IRB 4400, IRB 6600, IRB 6640, IRB 7600 |
| Signal Interface |
Serial encoder bus, compatible with ABB resolver and encoder systems |
| Operating Environment |
Industrial automation, automotive, foundry, food & beverage, electronics assembly |
| Maintenance Value |
Eliminates positional drift-induced unplanned downtime; stabilizes cycle time |
| Origin |
Sweden (ABB OEM) |
| Condition |
Tested & Verified — Ready for Immediate Deployment |
| Warranty |
warranty terms confirmed during quotation |
System Compatibility and Application
The 3HAC024775-001 SMB does not operate in isolation — it is the sensory backbone of the IRC5 motion control architecture. Understanding how it integrates with the broader automation ecosystem reveals why its condition directly determines the energy efficiency of the entire robot cell.
At the controller level, the IRC5 Main Computer (DSQC 639) processes the position data delivered by the SMB and translates it into real-time motion commands. When the SMB delivers clean, low-latency feedback, the DSQC 639 can execute smooth velocity profiles that minimize peak current draw during acceleration and deceleration phases. This directly reduces the load on the IRC5 Drive Unit (DSQC 601 / DSQC 617), which manages power conversion for all robot axes. A degraded SMB forces the drive unit to compensate with higher-frequency corrections, increasing switching losses and thermal output — both of which represent wasted energy.
The IRC5 Axis Computer (DSQC 668) coordinates multi-axis synchronization using the position data stream from the SMB. In applications where multiple robots share a coordinated workspace — such as automotive body-in-white welding lines — any degradation in SMB signal quality causes the axis computer to introduce conservative motion margins, slowing cycle times and reducing Overall Equipment Effectiveness (OEE). Restoring SMB integrity with a verified 3HAC024775-001 unit allows the axis computer to operate at its designed synchronization bandwidth, recovering lost production throughput without increasing energy input.
On the power supply side, the IRC5 Power Supply Unit (DSQC 609) regulates DC bus voltage for the drive system. Erratic encoder feedback creates irregular torque demand patterns that stress the power supply’s regulation circuits, causing micro-fluctuations in bus voltage that propagate across all connected servo drives. A stable SMB signal smooths this demand curve, extending the service life of the power supply and reducing harmonic distortion on the facility’s electrical network.
For facilities that have deployed ABB’s SafeMove safety controller or integrated the IRC5 with a PROFINET or DeviceNet fieldbus network, the SMB’s role becomes even more critical. SafeMove relies on redundant position monitoring — any inconsistency in SMB data triggers protective stops that halt production and waste the energy already invested in bringing the robot to operating temperature. Similarly, when the IRC5 communicates axis state data upstream to a SCADA or MES system via the DSQC 352 fieldbus adapter, corrupted position data from a failing SMB can trigger false alarms, unnecessary maintenance dispatches, and unplanned downtime — all of which carry hidden energy and operational costs.
In servo-intensive applications such as arc welding or precision assembly, the SMB works in concert with the ABB FlexPendant (IRC5 teach pendant) and the robot’s wrist resolver system to maintain sub-millimeter positional accuracy. This accuracy is what allows the IRC5 to execute energy-optimized motion paths — paths that have been programmed to minimize jerk, reduce peak torque, and complete tasks in the fewest possible motor revolutions. A compromised SMB undermines all of this path optimization work, forcing the controller to fall back on conservative, energy-inefficient motion profiles.
Maintenance and Replacement Notes
In automotive stamping and assembly plants, ABB IRC5-controlled robots are often running 20 hours per day across multiple shifts. In this context, the energy cost of a degraded Serial Measurement Board is not theoretical — it is measurable. When the SMB begins to fail, the IRC5 controller compensates by increasing servo gain, which raises the average current draw of each axis motor. Across a six-axis robot running at high duty cycle, this can represent a meaningful increase in per-shift energy consumption, compounded across every robot in the cell.
Predictive maintenance programs that monitor IRC5 error logs for SMB-related fault codes — such as axis calibration errors or resolver communication faults — can identify degrading boards before they cause unplanned stops. Replacing the 3HAC024775-001 proactively, during a scheduled maintenance window, avoids the far greater energy and productivity cost of an emergency shutdown: restarting a cold robot cell, re-homing all axes, and running warm-up cycles all consume significant energy that a timely SMB replacement would have prevented.
In electronics assembly lines where IRC5 robots perform high-speed pick-and-place operations, cycle time consistency is directly linked to energy efficiency. A robot that completes each cycle in exactly the programmed time draws a predictable, optimized amount of energy. SMB degradation introduces cycle time variance — some cycles run long as the controller waits for valid position confirmation, others trigger protective stops. This variance destroys the energy efficiency of the entire line, because conveyors, vision systems, and downstream equipment continue consuming power during the unplanned pauses.
All units supplied by ZYPLC undergo functional testing prior to shipment, verifying encoder signal integrity, communication bus response, and board-level power consumption. This pre-shipment validation ensures that the replacement 3HAC024775-001 will restore the IRC5 to its designed energy performance profile from the first power-on, without requiring extended commissioning or tuning cycles. Every unit is backed by a warranty terms confirmed during quotation, providing operational assurance for the full production season following installation.
Product Sourcing FAQ
Q1: How does replacing the 3HAC024775-001 SMB reduce energy consumption in an IRC5 robot cell?
A degraded SMB causes the IRC5 drive system to issue more frequent and higher-magnitude servo corrections to compensate for noisy or delayed position feedback. Each unnecessary correction draws additional current from the drive unit and increases thermal losses in the motor windings. A verified replacement SMB restores clean feedback, allowing the controller to execute smooth, energy-optimized motion profiles with minimal corrective overhead.
Q2: Is the 3HAC024775-001 compatible with all IRC5 controller variants?
The 3HAC024775-001 SMB is designed for the ABB IRC5 platform and is compatible with Single Cabinet, Dual Cabinet, and Panel Mounted IRC5 configurations. It supports a wide range of ABB robot models including the IRB 1600, IRB 2400, IRB 4400, IRB 6600, IRB 6640, and IRB 7600 series. If you are uncertain about compatibility with a specific robot configuration, please contact our technical team with your robot serial number and controller software version.
Q3: Can the 3HAC024775-001 replace the alternate part number 3HAC044168-001?
Yes. The 3HAC044168-001 is a revised part number for the same Serial Measurement Board function within the IRC5 platform. Both part numbers refer to functionally equivalent SMB assemblies. ZYPLC stocks both references and can confirm cross-compatibility for your specific robot and controller revision before shipment.
Q4: What does the warranty terms confirmed during quotation cover, and what is the testing process before shipment?
Every 3HAC024775-001 unit supplied by ZYPLC is tested for encoder signal integrity, serial communication bus response, and board-level power draw before shipment. The warranty terms confirmed during quotation covers functional failure under normal operating conditions, including defects in the board’s signal processing circuits, communication interfaces, and power regulation components. Units that fail within the warranty period are replaced or refunded. Our testing process is designed to replicate real IRC5 operating conditions, ensuring that the board you receive will perform reliably from installation through your next scheduled maintenance interval.