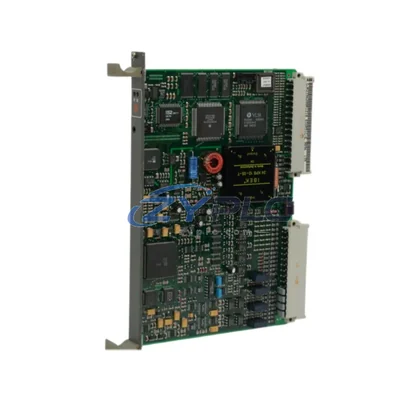
ABB 3HAC16035-1 Brake Release Board IRC5: Precision Brake Control for Optimized Production Line Efficiency
The ABB 3HAC16035-1 is a dedicated Brake Release Board Module engineered for the ABB IRC5 robot controller platform. In modern industrial automation environments where energy efficiency, uptime, and production throughput are mission-critical, this module plays a pivotal role in managing motor brake engagement and disengagement with precision timing — directly reducing unplanned downtime risk, mechanical wear, and unplanned downtime across robotic production cells.
Unlike generic brake control solutions, the 3HAC16035-1 is purpose-built for ABB’s IRC5 architecture, ensuring seamless integration with the IRC5 single-cabinet and dual-cabinet controller variants. Its deterministic brake release logic eliminates the unplanned downtime associated with prolonged brake hold states, allowing servo motors to transition efficiently between locked and active states without abnormal load draw or thermal stress on drive components.
Product Specification Table
| Parameter |
Specification / Value |
| Part Number / SKU |
3HAC16035-1 |
| Compatible Platform |
ABB IRC5 Robot Controller (Single & Dual Cabinet) |
| Module Function |
Motor Brake Release Control |
| Operating Voltage |
24 VDC (nominal, IRC5 internal bus) |
| Power Consumption |
Low-standby design; brake hold current minimized during idle states |
| Drive Compatibility |
ABB DSQC series drive units; IRC5 axis computer interface |
| Application Environment |
Industrial robotic cells, automotive assembly, material handling, arc welding lines |
| Energy Saving Value |
Reduces unnecessary brake energization cycles; lowers thermal load on servo drives |
| Origin |
Sweden (ABB Robotics) |
| Warranty |
warranty terms confirmed during quotation — tested before shipment |
| Stock Status |
RFQ Available — shipment arranged after confirmation |
System Compatibility and Application
The 3HAC16035-1 Brake Release Board does not operate in isolation — it is a functional node within a tightly integrated industrial automation system. In a typical IRC5-based robotic cell, the ABB DSQC661 Axis Computer coordinates motion commands and communicates brake status signals to this board, ensuring that brake release events are synchronized with servo torque readiness. This synchronization prevents the energy spike that occurs when a brake is released before the drive has reached holding torque, a common source of wasted energy and mechanical shock in poorly tuned systems.
On the drive side, the ABB DSQC662 Drive Unit and ABB DSQC663 Drive Module work in tandem with the brake board to regulate motor current during the transition from braked to active states. When the 3HAC16035-1 signals brake release, the drive unit ramps current smoothly, reducing inrush energy and extending motor winding life. In multi-axis configurations, the ABB DSQC609 Power Supply Unit ensures stable 24 VDC delivery to the brake release circuitry, preventing voltage sag that could cause false brake engagement during high-load cycles.
For facilities running condition monitoring programs, the brake release board integrates within systems that include the ABB DSQC643 I/O Board for digital status feedback and the ABB DSQC377B Panel Board for operator-level brake override functions. These components feed real-time brake state data into the IRC5’s internal logging system, which can be accessed via the ABB FlexPendant (DSQC679) for on-floor diagnostics without halting production. In larger facilities, this data is aggregated through ABB RobotStudio or third-party SCADA platforms via DeviceNet or EtherNet/IP communication modules such as the DSQC612, enabling plant-level energy dashboards to track brake cycle frequency as a proxy for drive wear and energy efficiency trends.
Maintenance and Replacement Notes
In high-cycle robotic applications — such as automotive spot welding, press tending, or palletizing lines — the brake release board’s role in maintenance planning becomes measurable. Each unnecessary brake engagement cycle consumes energy to hold the brake coil energized and generates heat in the brake resistor circuit. The 3HAC16035-1’s precision control logic minimizes dwell time in transitional states, reducing the number of partial-cycle brake events that accumulate into significant unplanned downtime over a production shift.
From a maintenance cost perspective, optimized brake control directly extends the service life of motor brake assemblies on ABB IRB series robots. Fewer thermal stress cycles on the brake coil mean longer mean time between replacements (MTBR), reducing both parts cost and the labor associated with brake module changeouts. In facilities tracking Overall Equipment Effectiveness (OEE), a reduction in brake-related micro-stoppages — where a robot pauses due to brake timing errors — translates directly into improved availability scores and higher throughput per shift.
For predictive maintenance programs, the brake release board’s digital feedback signals can be monitored for anomalies such as delayed release confirmation or increased release current, which are early indicators of brake wear or coil degradation. Integrating this data into a condition monitoring workflow allows maintenance teams to schedule brake servicing during planned downtime windows rather than reacting to unplanned failures — a key lever for reducing unplanned downtime from emergency restarts and production recovery cycles.
Every unit of the ABB 3HAC16035-1 supplied by ZYPLC undergoes functional testing prior to shipment, verifying brake release signal integrity, coil drive output, and interface compatibility with the IRC5 controller bus. Stock is maintained for shipment arranged after confirmation, supporting urgent replacement needs without extended lead times that would otherwise force production lines into extended idle states — themselves a source of unplanned downtime and lost output.
Product Sourcing FAQ
Q1: How does the ABB 3HAC16035-1 contribute to operational stability in an IRC5 robotic cell?
The 3HAC16035-1 minimizes unnecessary brake energization by precisely timing brake release and engagement in coordination with the IRC5 axis computer and drive units. This reduces coil hold current during idle periods and eliminates energy-wasting transitional states, lowering overall cell power consumption during multi-shift operations.
Q2: Is the 3HAC16035-1 compatible with all IRC5 controller variants?
Yes. The 3HAC16035-1 is designed for the ABB IRC5 platform, including single-cabinet, dual-cabinet, and IRC5 Compact variants. It interfaces with the standard IRC5 internal bus and is compatible with DSQC-series axis computers and drive units used across ABB IRB robot families.
Q3: What is the recommended replacement procedure and how does it affect production downtime?
Replacement requires powering down the IRC5 controller, disconnecting the brake board connector harness, and swapping the module — typically a 15–30 minute procedure for a trained technician. Using a pre-tested replacement unit from ZYPLC stock eliminates the burn-in period required for untested boards, allowing faster return to production and minimizing unplanned downtime from extended idle restarts.
Q4: What warranty and testing does ZYPLC provide for the 3HAC16035-1?
All ABB 3HAC16035-1 units supplied by ZYPLC carry a warranty terms confirmed during quotation and are functionally tested before shipment to verify brake release signal output, interface compatibility, and coil drive performance. This ensures the module performs to specification from the first power-on, reducing commissioning time and the risk of energy-wasting fault recovery cycles.