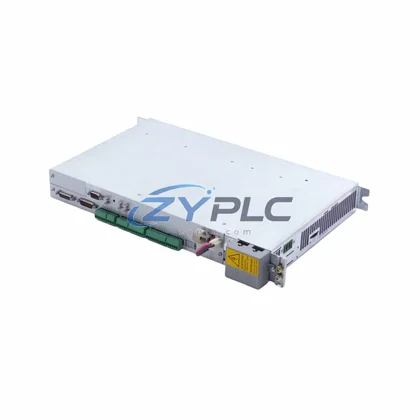
Parker C3S038V4F10I20T40M00: Industrial Data Link for Compax3 Smart Factory Connectivity
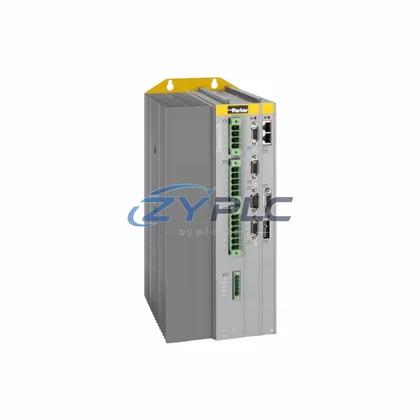
The Parker C3S038V4F10I20T40M00 is a high-performance single-axis servo drive from the renowned Compax3 series, engineered to serve as a critical industrial network interface node within modern smart factory architectures. Designed for demanding motion control applications, this drive integrates seamlessly into multi-protocol industrial communication environments — bridging field-level devices, PLC controllers, remote I/O modules, HMI panels, SCADA systems, variable frequency drives, precision sensors, and upper-level MES/ERP platforms into a unified, real-time data fabric.
At its core, the C3S038V4F10I20T40M00 supports EtherCAT fieldbus communication — one of the fastest and most deterministic industrial Ethernet protocols available — enabling sub-millisecond cycle times essential for synchronized multi-axis motion, high-speed packaging lines, and precision assembly automation. The drive’s I20 interface designation confirms its advanced fieldbus capability, allowing it to act as a gateway node that translates servo-level motion data into structured network packets consumable by SCADA historians, OPC-UA servers, and cloud-based analytics platforms.
Compatibility & Integration Notes
| Parameter |
Specification |
| Communication Protocol |
EtherCAT (IEC 61158), CANopen over EtherCAT (CoE) |
| Interface Type |
I20 Fieldbus Interface Module, RJ45 Industrial Ethernet |
| Transmission Capability |
100 Mbit/s, real-time deterministic, <1 ms cycle time |
| Network Compatibility |
EtherCAT Master/Slave topology, daisy-chain, star |
| System Application |
SCADA, HMI, PLC, Remote I/O, MES, OPC-UA Gateway |
| Voltage Class |
V4 (400 VAC three-phase) |
| Continuous Current |
3.8 A (038 designation) |
| Feedback Type |
F10 — Resolver / Encoder feedback |
| Warranty |
warranty terms confirmed during quotation — All units tested before shipment |
| Origin |
Parker Hannifin, CN availability subject to RFQ confirmation |
Connected Automation Data Flow
In a typical smart factory deployment, the C3S038V4F10I20T40M00 sits at the intersection of motion execution and network intelligence. Signal acquisition begins at the sensor layer — linear encoders, torque transducers, and proximity switches feed real-time position and velocity data directly into the drive’s F10 feedback interface. This data is processed locally within the Compax3’s onboard motion engine before being encapsulated into EtherCAT frames and transmitted upstream.
The drive operates in coordinated motion networks alongside companion axes such as the Parker C3S025V4F10I20T40M00 (2.5 A variant) and the Parker C3S063V4F10I20T40M00 (6.3 A variant), enabling synchronized multi-axis gantry, pick-and-place, and winding applications where all axes share a common EtherCAT master clock. The Parker C3F038V4F10I20T40M00 force-control variant can be integrated in parallel for press-fit and assembly force monitoring tasks on the same network segment.
At the controller level, a Parker ACR9000 multi-axis motion controller or a third-party EtherCAT master PLC (such as Beckhoff CX series or Siemens S7-1500 with EtherCAT CM) issues cyclic position, velocity, and torque setpoints to the C3S038V4F10I20T40M00 via PDO (Process Data Object) mapping. Simultaneously, the Parker CPX-FB41 EtherCAT fieldbus module can be deployed on the same network ring to extend I/O connectivity to remote pneumatic valve islands and distributed sensor clusters without additional wiring infrastructure.
HMI visualization is achieved through Parker IHM series panels or third-party SCADA clients (Wonderware, iFIX, Ignition) connected via OPC-UA adapters that subscribe to the drive’s real-time status registers — including actual torque, following error, thermal load, and fault codes. The Parker Compax3 ServoManager software provides the engineering layer for drive parameterization, motion program upload, and network node commissioning, while also serving as a diagnostic gateway for remote access sessions over VPN-secured industrial Ethernet.
Variable frequency drives such as the Parker AC30 series can coexist on the same EtherCAT segment for coordinated speed control of conveyor and pump loads, with the C3S038V4F10I20T40M00 providing the precision servo motion for positioning tasks while the AC30 handles continuous process loads — all orchestrated by a single PLC master with deterministic scan times.
Edge gateway devices — such as the Parker EM4 embedded motion controller — can aggregate data from multiple Compax3 drives and publish structured JSON payloads to MQTT brokers or REST APIs, enabling cloud-based predictive maintenance dashboards to monitor bearing wear, winding temperature trends, and regenerative energy recovery metrics across entire production lines.
Solving Data Isolation in Industrial Sites
Legacy industrial sites frequently suffer from protocol fragmentation: servo drives speaking proprietary RS-232 or analog ±10 V command interfaces cannot communicate directly with modern EtherCAT or PROFINET-based PLC platforms, creating data silos that prevent real-time production visibility. The C3S038V4F10I20T40M00 eliminates this barrier by providing a native EtherCAT interface that integrates directly into standard IEC 61131-3 PLC programming environments without protocol converters or middleware.
For sites with mixed-protocol legacy equipment, the Compax3’s onboard gateway functionality — combined with external protocol bridges — allows PROFIBUS DP, DeviceNet, and CANopen devices to be mapped into the EtherCAT domain, presenting a unified process image to the SCADA historian. This enables production line transparency: every axis position, torque value, cycle count, and alarm event is timestamped and logged, supporting OEE (Overall Equipment Effectiveness) calculations and ISO 22400 KPI reporting without manual data entry.
Remote diagnostics are supported through the drive’s built-in web server and Modbus TCP secondary interface, allowing maintenance engineers to interrogate fault logs, adjust PID parameters, and perform oscilloscope captures of velocity and current waveforms from any networked workstation — reducing mean time to repair (MTTR) and eliminating the need for on-site service visits for first-level fault analysis. System expansion is straightforward: additional Compax3 axes are daisy-chained on the EtherCAT ring with automatic node address assignment, and the master PLC’s axis count can be scaled without hardware changes to the network infrastructure.
Industrial Connectivity FAQ
Q1: What is the communication latency of the C3S038V4F10I20T40M00 on an EtherCAT network?
The Compax3 I20 EtherCAT interface supports cycle times as low as 250 µs in distributed clock mode, with typical application cycle times of 1–4 ms for multi-axis coordinated motion. Jitter is sub-microsecond, meeting the determinism requirements of IEC 61784-2 for real-time motion control.
Q2: Is the C3S038V4F10I20T40M00 compatible with third-party EtherCAT masters and SCADA systems?
Yes. The drive implements the CANopen over EtherCAT (CoE) device profile (CiA 402), making it compatible with any conformant EtherCAT master including Beckhoff TwinCAT, Omron Sysmac, Siemens S7-1500 CM EtherCAT, and open-source masters such as SOEM. SCADA integration is achieved via OPC-UA, Modbus TCP, or direct database connectors available in platforms such as Ignition, Wonderware, and iFIX.
Q3: How does the drive handle network instability or communication interruptions?
The C3S038V4F10I20T40M00 implements configurable watchdog timers on the EtherCAT communication channel. Upon detection of a communication timeout, the drive executes a programmable safe-state response — including controlled deceleration to zero velocity, torque disable, or hold-position — before generating a network fault alarm visible on the SCADA alarm management console. Automatic reconnection is supported upon restoration of the EtherCAT link without requiring a full system restart.
Q4: What warranty and pre-shipment testing does ZYPLC provide for this unit?
All Parker C3S038V4F10I20T40M00 units supplied by ZYPLC carry a warranty terms confirmed during quotation covering manufacturing defects and functional failures under normal operating conditions. Every unit undergoes functional power-on testing, communication interface verification, and parameter integrity checks prior to shipment. Availability is confirmed via RFQ for same-week dispatch with full test documentation provided upon request.